Real-Time Vision and Motion Control
Sep 1, 2023
·
1 min read
Robotics · Computer Vision · Motion Control
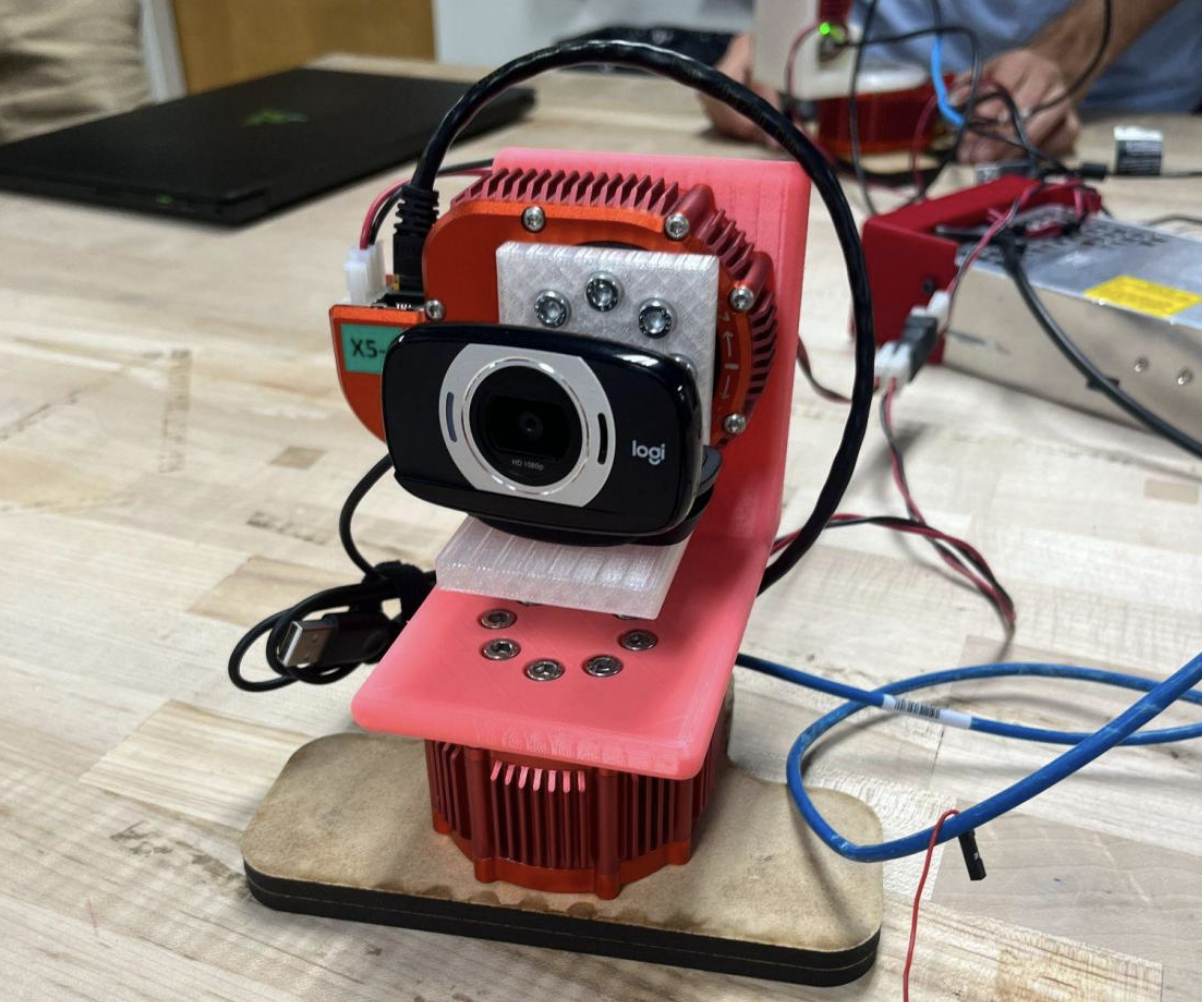
I worked on a real-time camera-guided tracking system that used Python/OpenCV target detection and HEBI actuator control to move a pan–tilt platform smoothly.
Python
OpenCV
HEBI actuators
Target tracking
Pan–tilt control
Spline-based motion
Project Work
This project connected computer vision, motion control, and hardware integration. I used Python/OpenCV to detect and track a target from camera input, then connected the visual target position to motion commands for a HEBI pan–tilt actuator setup. I also worked on smooth pan–tilt motion, live tracking tests, mechanical assembly, bracket setup, and tuning the system around practical hardware behavior.

Authors
Mechanical Engineering Student
I am a mechanical engineering student at Caltech interested in robotics, controls,
aerial systems, and multi-modal robot platforms. My work focuses on building and
testing physical robotic systems through flight-control integration, prototyping,
aerodynamic testing, sensing, and experimental validation.